Engineering Embodied Intelligence.
I bridge large neural architectures with constrained physical silicon. From formulating analytical Inverse Kinematics and OpenCV visual servoing for autonomous pick-and-place robotic arms to quantizing large language models for sub-second execution on a single Raspberry Pi 5.
Bringing Large Models to Raw Silicon
For an embodied robotic system to converse and make decisions without external network dependency, large neural architectures must fit within stringent memory, thermal, and compute constraints.
Bringing Llama-3 to the Edge: End-to-End Quantized Conversational AI on Raspberry Pi 5
Engineered an on-device voice-to-voice conversational intelligence pipeline integrating Whisper automatic speech recognition (ASR), a quantized 3B Llama-3 model, and neural text-to-speech (TTS), executing fully on-device on a Raspberry Pi 5 without external API dependencies. This architecture serves as the computational backbone for untethered robotic agents operating in compute-constrained environments.
| Host SoC | Broadcom BCM2712 |
| CPU Cores | 4x ARM Cortex-A76 @ 2.4GHz |
| Vector Unit | 128-bit ARM NEON SIMD |
| RAM Pool | 8GB LPDDR4X (Shared) |
| OS & Kernel | Raspberry Pi OS (64-bit Linux) |
| Deployment | Untethered Edge Autonomy |
From Cognition to Kinematics
Intelligence must manipulate and navigate the physical world. Simulating contact dynamics, solving forward and inverse kinematics, and actuating real motors.
Autonomous Vision-Guided Pick-and-Place Robotic Arm
Engineered an autonomous pick-and-place system for a multi-DOF articulated robotic arm in ROS 2 (Humble) and Gazebo. Formulated closed-form analytical Forward and Inverse Kinematics (FK/IK) delivering deterministic sub-millimeter trajectory execution (<80 μs compute time), integrated with an eye-in-hand OpenCV computer vision pipeline (dual-band HSV chrominance segmentation and spatial moment centroid extraction) for closed-loop visual servoing and dynamic object acquisition.
Architectures Built From First Principles
Deep learning pipelines, machine translation from scratch, vector similarity search, and active tooling.
Media Tracker
A centralized utility to log, analyze, and manage multi-platform media consumption, metadata extraction, and archival records.
Transformer Model from Scratch
Implemented a complete Transformer architecture for English-to-French machine translation from first principles without high-level seq2seq wrappers.
Image Similarity Search Engine
High-throughput visual retrieval engine coupling ResNet50 deep feature representations with Facebook AI Similarity Search (FAISS) for sub-millisecond nearest-neighbor search.
Pneumonia Detection from Chest X-Rays
Trained convolutional neural network classifiers on radiological X-ray datasets with data augmentation pipelines and precision-recall threshold optimization.
Technical Competencies
Grouped across physical robotics simulation, on-device silicon deployment, and core machine learning.
Robotics & Simulation
Edge AI & Embedded Silicon
Machine Learning & Systems
The Written Word
Critical reflections on machine intelligence, industry hype, and personal essays on technology.
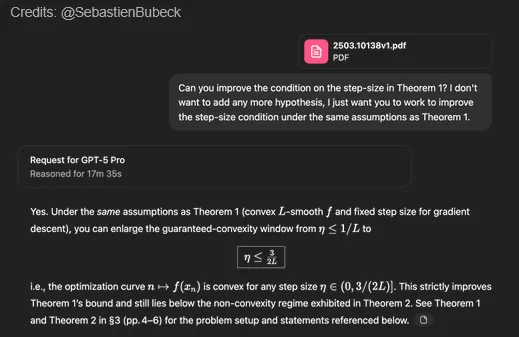
Is it smarter than a PhD holder? Count the Rs in 'Strawberry'.
Read on Substack ↗
Get In Touch
Available for AI R&D engineering, robotics initiatives, and edge inference collaborations.
I also lead a parallel creative life as an author, actor, video editor, and theatre director. You can explore my creative productions, short stories, and music videos on the creative portal.